American sign language interpreter
[Spring 2025] ECE 5730 Final ProjectBy Shi Gu (sg2562), Lulu Htutt (lh543), and Sana Chawla (sc2347).
- Suitable forB.Tech/B.E Embedded Systems students
- Build time4-6 weeks
- LevelIntermediate
- Available atAjvika Labs, Kakinada
About this project
Toggle navigation
Introduction
High Level Design
Result
ASL Interpreter
ECE 5730 Final Project
Demonstration Video
Introduction
For our final project we designed and developed a glove based system that can detect the alphabets of
the
American Sign Language (ASL) using flex sensors and an IMU.
We created
this system to provide an affordable alternative to expensive commercial sign language translation
systems,
making communication more accessible for individuals who are non-verbal, hard of hearing, or deaf. The
project
uses a Raspberry Pi Pico to process sensor data from five flex sensors (one for each finger), contact
sensors
and an MPU6050 IMU
to detect hand orientation, implementing threshold-based signal processing to detect the ASL alphabet.
High Level Design
Rationale and Sources
We chose a glove‐based ASL interpreter because wearable sensors offer a low‐cost
alternative to camera-based vision systems - no special lighting, no privacy concerns, and no heavy
image
processing. Flex sensors directly measure finger bends and an IMU captures hand orientation, allowing
real-time alphabet detection on a lightweight microcontroller. This approach makes translation
accessible to users in any environment, including those with limited internet or compute resources.
We found a couple of projects in the past years of this
class that were similar to our idea, and we referenced them when we ran into blocks.
Fall 2018: aac94_kd333_rp426
Fall 2014: rdv28_mjl256
Hardware Design
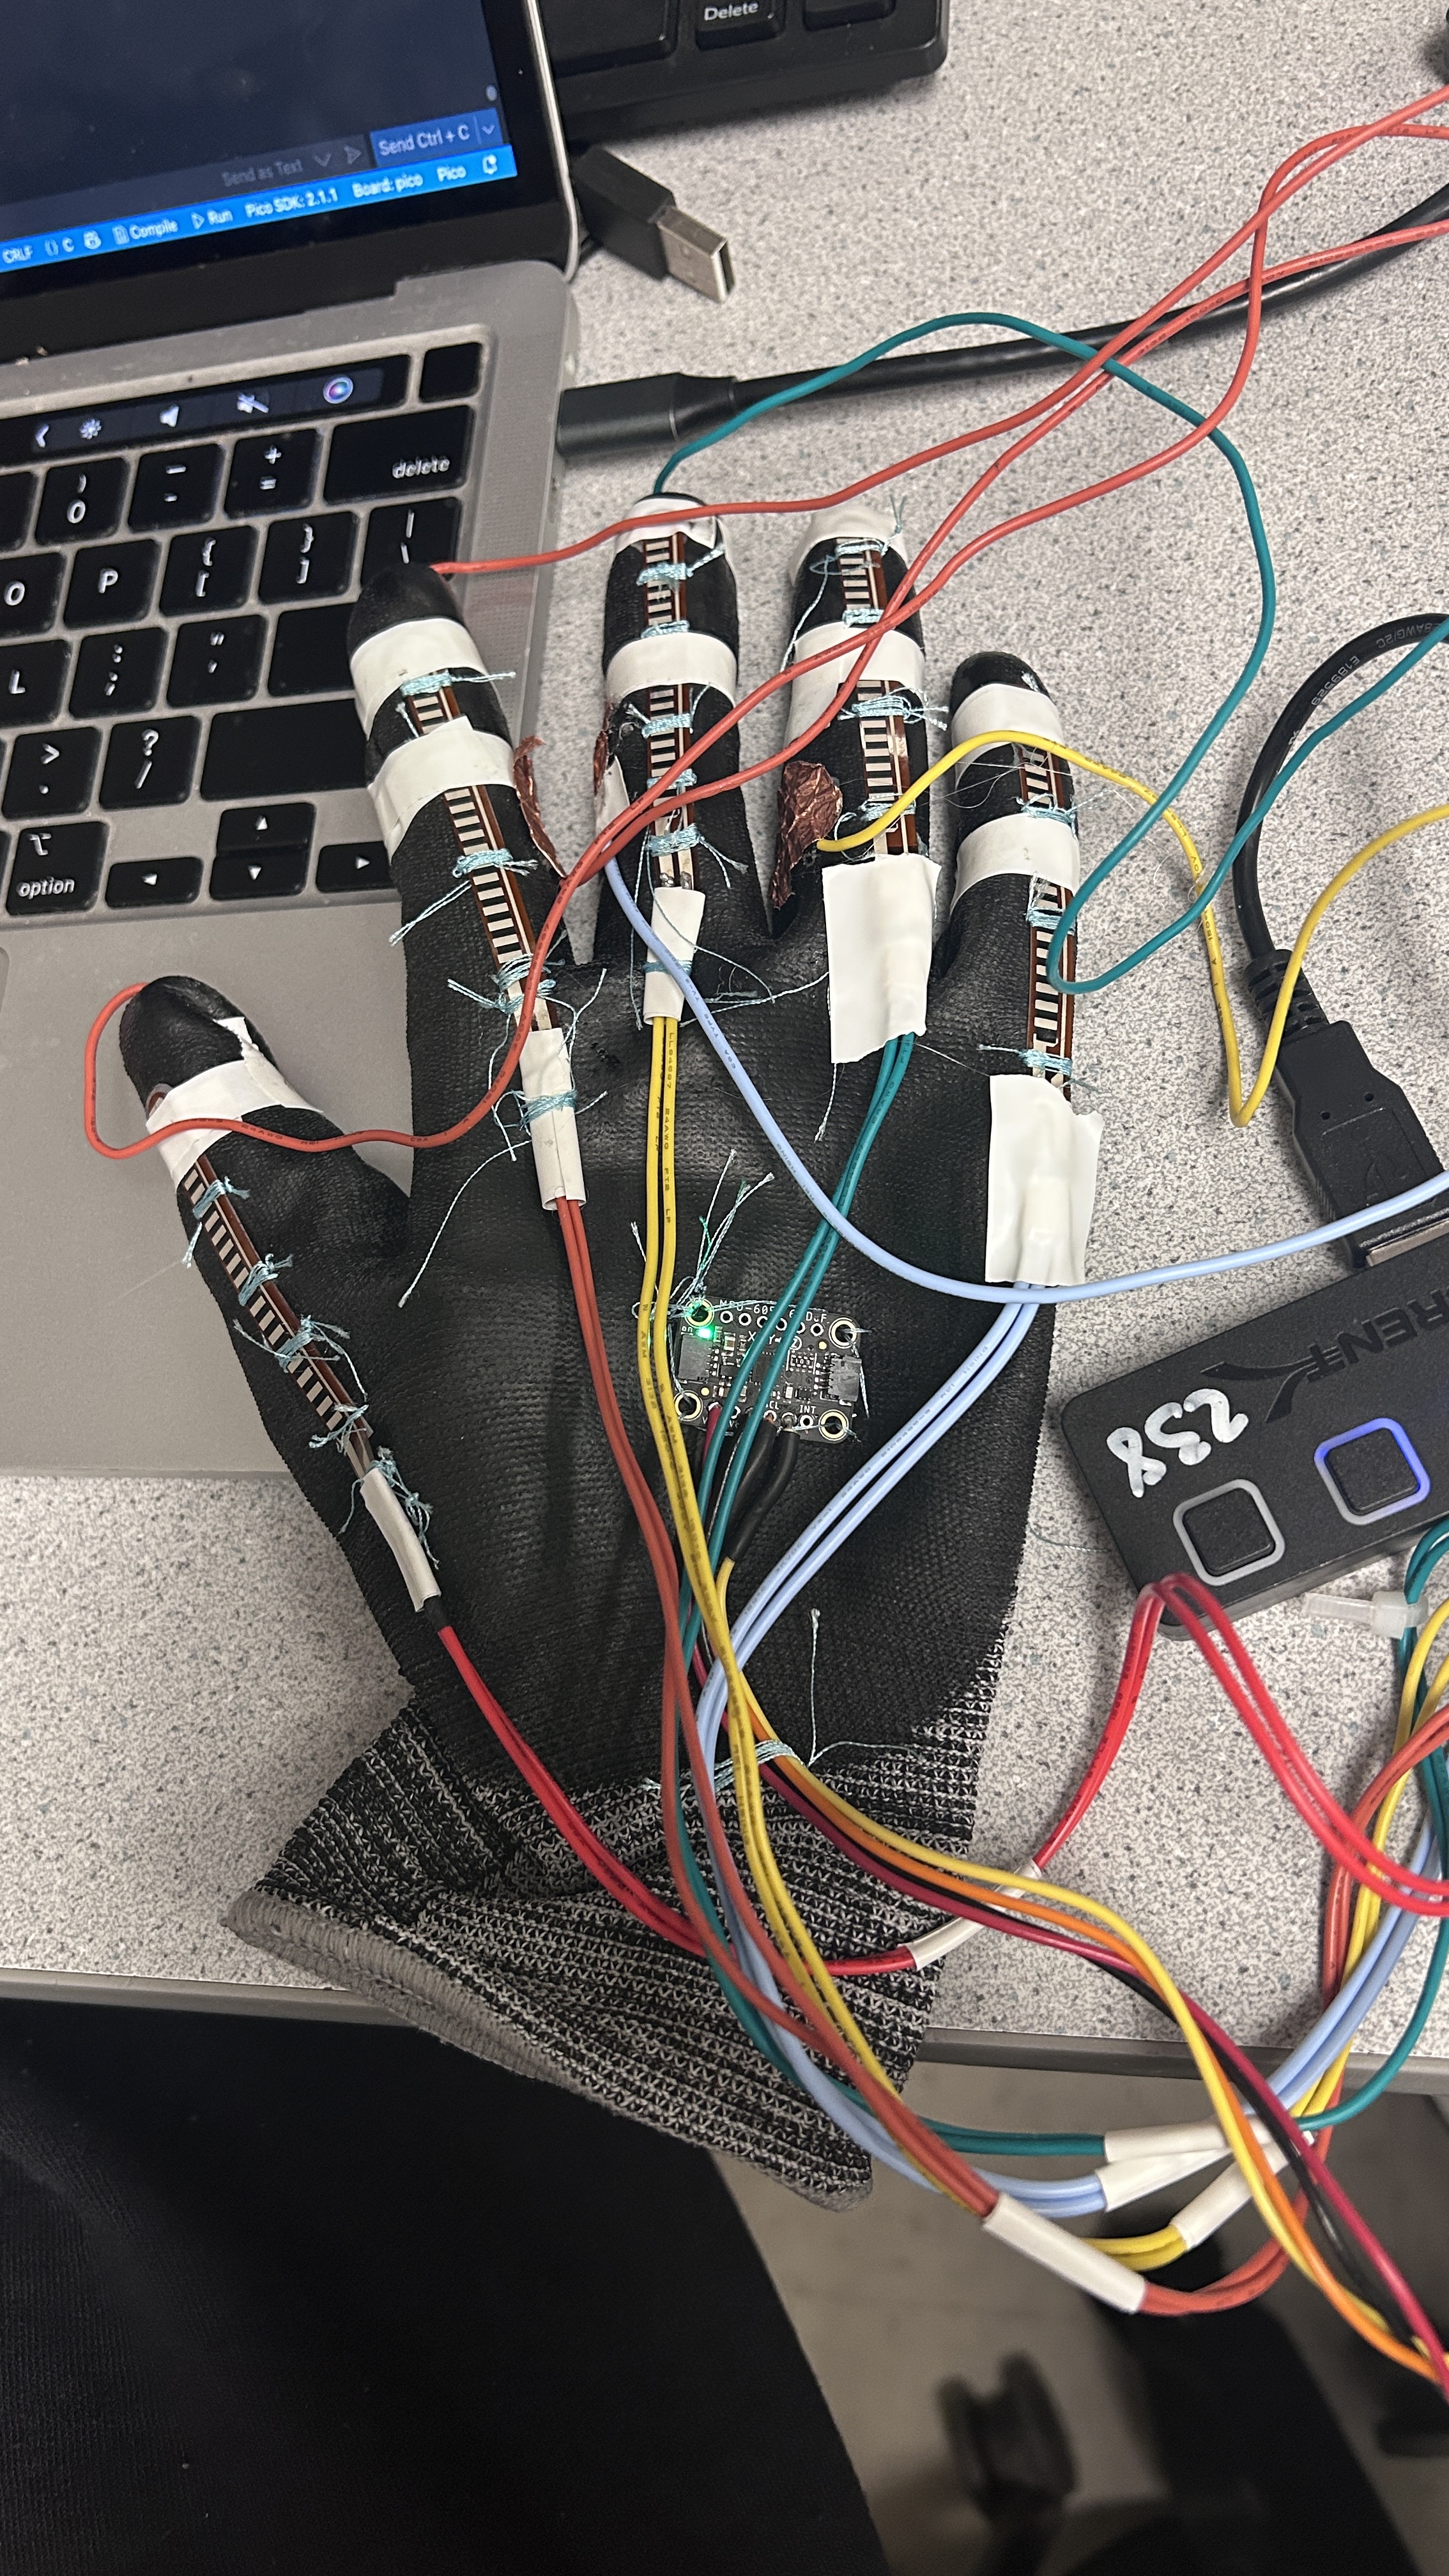
Our hardware includes a glove with 3 different kinds of sensors for detecting gestures of each letter in
ASL alphabet.
The following is the picture of our final project:
Picture of the final project
Circuit Diagram of ASL Interpreter
We placed five flex sensors on the top of each finger to detect individual finger bending.
The resistance of a flex sensor increases when it is bent, allowing it to act as a variable resistor.
By connecting each sensor in a voltage divider configuration with a pull-down resistor,
we can convert the resistance change into a measurable voltage.
The output voltage is then read by the microcontroller to determine the degree of bending.
To maximize sensitivity, we selected the pull-down resistor values based on the unbent resistance of
each flex sensor.
One sensor had a much higher baseline resistance (~90 kΩ), while the others measured closer to ~60 kΩ.
We chose resistor values that are comparable to these resistances to ensure a larger voltage swing in
response
to bending, which is helpful for our detection accuracy.
For reading all 5 values of each flex sensor, we used an external 10-bit 8-channel Analogue-to-Digital
Converter (ADC) with SPI protocol.
Raspberry Pi Pico with RP2040 has 3 ADC reading pins which is not enough for 5 readings. Since gesture
detection
does not need high-speed or real-time sampling, we used an 8-channel ADC which has an internal
multiplexer to
sequentially return readings of each ADC channel.
We used a Inertial Measurement Unit (IMU), specifically MPU6050, to detect the rotation and motion of
the hand.
It was placed at the center of the back of the glove and communicates with Raspberry Pi via I2C
protocol.
The IMU contains both an accelerometer and a gyroscope.
The accelerometer provides acceleration readings along three axes, which can be used to estimate
orientation,
while the gyroscope measures angular velocity along the same axes to detect motion.
Both types of data are essential for accurate gesture recognition because some letters have the same
fingers bent but differ
in hand orientations, such as P and K, and some letters are dynamic such as J and Z.
Contact sensors are employed to detect contacts. Below is the configuration of our contact sensors:
Contact Sensor Configuration - Each circle represents a copper foil (Red indicates 3.3 V, and Green
are GPIO inputs)
The sensors are configured in a pull-up way. The red circles are copper foils wired to 3.3 V power pin,
while the green circles are
copper foils connected to GPIO inputs. As red and green contacts, the GPIO input should return a HIGH
reading, indicating two fingers contact.
This is useful to identify letters that differ only in fingers contact such as U and V.
Beside sensors for detecting gesture, VGA and a button is used to display the corresponding letters
detected. We connected a Raspberry Pi debugger to
print detected letters on the serial monitor. And the user can press the button to print the letter
detected to the VGA screen. Below is an example of
printed "HELLO WORLD".
HELLO WORLD printed on VGA screen
Software Design
Gesture Recognition Framework
We implemented a structured approach to match hand positions to predefined signs using a comprehensive
data
structure. Each gesture is defined by a combination of finger positions (categorized as straight,
half-bent, or
fully bent for each finger), hand orientation data from the IMU (when applicable), and contact points
between
fingers (detected through contact sensors). This structured representation allows us to efficiently
compare
incoming sensor data against our library of recognized signs.
Mathematical Foundation
The system relies on several mathematical techniques to process sensor data accurately. We utilize 15.16
fixed-point representation for all our calculations, which allocates 15 bits for the integer part and 16
bits
for the fractional part. This approach achieves high precision while avoiding the computational overhead
of
floating-point operations on the microcontroller.
To reduce noise in accelerometer readings, we implement a first-order IIR (Infinite Impulse Response)
low-pass
filter. This filter is described by the equation: y[n] = α·y[n-1] + (1-α)·x[n], where y[n] is the
filtered
output, y[n-1] is the previous filtered value, x[n] is the current input, and α is a smoothing factor
(0.35 in
our implementation). We optimize this calculation using bit-shifting operations to improve performance
on the
microcontroller.
For determining hand orientation, we use arctangent functions on the accelerometer data. Specifically,
we
calculate pitch (rotation around the y-axis) using atan2(-ax, az), roll (rotation around the x-axis)
using
atan2(az, -ay), and yaw (rotation around the z-axis) using atan2(ax, ay). These calculations convert the
raw
accelerometer readings into meaningful angular measurements in degrees, which are essential for
distinguishing
between gestures with similar finger positions but different hand orientations.
Additionally, we implemented a complementary filter that combines accelerometer and gyroscope data to
achieve
more stable orientation tracking. This filter is described by the equation: angle = 0.999 × (angle +
gyro_data ×
dt) + 0.001 × accel_angle. The gyroscope provides accurate short-term measurements but suffers from
drift over
time, while the accelerometer provides absolute but noisy orientation references. The complementary
filter
leverages the strengths of both sensors to provide a more reliable orientation estimate.
Gesture Detection Pipeline
High-level diagram of the gesture detection process
Our gesture detection follows a sophisticated pipeline that begins with sensor data acquisition, where
we read
raw values from the flex sensors and IMU at a consistent sampling rate. The system then applies signal
processing techniques, including the aforementioned filtering and averaging methods, to reduce noise and
extract
meaningful features from the raw data.
In the feature extraction stage, we convert these processed readings into meaningful descriptors. For
flex
sensors, we categorize finger positions into three states (straight, half-bent, or fully bent) based on
carefully calibrated threshold values that were determined through experimental testing. For IMU data,
we
convert raw accelerometer and gyroscope readings into angular measurements that describe the hand's
orientation
in three-dimensional space.
The gesture classification stage is where the system matches these extracted features against our
predefined
gesture patterns. This matching process follows a hierarchical approach: first, it checks if the flex
sensor
patterns match; then, if contact sensors are used for a gesture, it verifies th
Introduction
High Level Design
Result
ASL Interpreter
ECE 5730 Final Project
Demonstration Video
Introduction
For our final project we designed and developed a glove based system that can detect the alphabets of
the
American Sign Language (ASL) using flex sensors and an IMU.
We created
this system to provide an affordable alternative to expensive commercial sign language translation
systems,
making communication more accessible for individuals who are non-verbal, hard of hearing, or deaf. The
project
uses a Raspberry Pi Pico to process sensor data from five flex sensors (one for each finger), contact
sensors
and an MPU6050 IMU
to detect hand orientation, implementing threshold-based signal processing to detect the ASL alphabet.
High Level Design
Rationale and Sources
We chose a glove‐based ASL interpreter because wearable sensors offer a low‐cost
alternative to camera-based vision systems - no special lighting, no privacy concerns, and no heavy
image
processing. Flex sensors directly measure finger bends and an IMU captures hand orientation, allowing
real-time alphabet detection on a lightweight microcontroller. This approach makes translation
accessible to users in any environment, including those with limited internet or compute resources.
We found a couple of projects in the past years of this
class that were similar to our idea, and we referenced them when we ran into blocks.
Fall 2018: aac94_kd333_rp426
Fall 2014: rdv28_mjl256
Hardware Design
Our hardware includes a glove with 3 different kinds of sensors for detecting gestures of each letter in
ASL alphabet.
The following is the picture of our final project:
Picture of the final project
Circuit Diagram of ASL Interpreter
We placed five flex sensors on the top of each finger to detect individual finger bending.
The resistance of a flex sensor increases when it is bent, allowing it to act as a variable resistor.
By connecting each sensor in a voltage divider configuration with a pull-down resistor,
we can convert the resistance change into a measurable voltage.
The output voltage is then read by the microcontroller to determine the degree of bending.
To maximize sensitivity, we selected the pull-down resistor values based on the unbent resistance of
each flex sensor.
One sensor had a much higher baseline resistance (~90 kΩ), while the others measured closer to ~60 kΩ.
We chose resistor values that are comparable to these resistances to ensure a larger voltage swing in
response
to bending, which is helpful for our detection accuracy.
For reading all 5 values of each flex sensor, we used an external 10-bit 8-channel Analogue-to-Digital
Converter (ADC) with SPI protocol.
Raspberry Pi Pico with RP2040 has 3 ADC reading pins which is not enough for 5 readings. Since gesture
detection
does not need high-speed or real-time sampling, we used an 8-channel ADC which has an internal
multiplexer to
sequentially return readings of each ADC channel.
We used a Inertial Measurement Unit (IMU), specifically MPU6050, to detect the rotation and motion of
the hand.
It was placed at the center of the back of the glove and communicates with Raspberry Pi via I2C
protocol.
The IMU contains both an accelerometer and a gyroscope.
The accelerometer provides acceleration readings along three axes, which can be used to estimate
orientation,
while the gyroscope measures angular velocity along the same axes to detect motion.
Both types of data are essential for accurate gesture recognition because some letters have the same
fingers bent but differ
in hand orientations, such as P and K, and some letters are dynamic such as J and Z.
Contact sensors are employed to detect contacts. Below is the configuration of our contact sensors:
Contact Sensor Configuration - Each circle represents a copper foil (Red indicates 3.3 V, and Green
are GPIO inputs)
The sensors are configured in a pull-up way. The red circles are copper foils wired to 3.3 V power pin,
while the green circles are
copper foils connected to GPIO inputs. As red and green contacts, the GPIO input should return a HIGH
reading, indicating two fingers contact.
This is useful to identify letters that differ only in fingers contact such as U and V.
Beside sensors for detecting gesture, VGA and a button is used to display the corresponding letters
detected. We connected a Raspberry Pi debugger to
print detected letters on the serial monitor. And the user can press the button to print the letter
detected to the VGA screen. Below is an example of
printed "HELLO WORLD".
HELLO WORLD printed on VGA screen
Software Design
Gesture Recognition Framework
We implemented a structured approach to match hand positions to predefined signs using a comprehensive
data
structure. Each gesture is defined by a combination of finger positions (categorized as straight,
half-bent, or
fully bent for each finger), hand orientation data from the IMU (when applicable), and contact points
between
fingers (detected through contact sensors). This structured representation allows us to efficiently
compare
incoming sensor data against our library of recognized signs.
Mathematical Foundation
The system relies on several mathematical techniques to process sensor data accurately. We utilize 15.16
fixed-point representation for all our calculations, which allocates 15 bits for the integer part and 16
bits
for the fractional part. This approach achieves high precision while avoiding the computational overhead
of
floating-point operations on the microcontroller.
To reduce noise in accelerometer readings, we implement a first-order IIR (Infinite Impulse Response)
low-pass
filter. This filter is described by the equation: y[n] = α·y[n-1] + (1-α)·x[n], where y[n] is the
filtered
output, y[n-1] is the previous filtered value, x[n] is the current input, and α is a smoothing factor
(0.35 in
our implementation). We optimize this calculation using bit-shifting operations to improve performance
on the
microcontroller.
For determining hand orientation, we use arctangent functions on the accelerometer data. Specifically,
we
calculate pitch (rotation around the y-axis) using atan2(-ax, az), roll (rotation around the x-axis)
using
atan2(az, -ay), and yaw (rotation around the z-axis) using atan2(ax, ay). These calculations convert the
raw
accelerometer readings into meaningful angular measurements in degrees, which are essential for
distinguishing
between gestures with similar finger positions but different hand orientations.
Additionally, we implemented a complementary filter that combines accelerometer and gyroscope data to
achieve
more stable orientation tracking. This filter is described by the equation: angle = 0.999 × (angle +
gyro_data ×
dt) + 0.001 × accel_angle. The gyroscope provides accurate short-term measurements but suffers from
drift over
time, while the accelerometer provides absolute but noisy orientation references. The complementary
filter
leverages the strengths of both sensors to provide a more reliable orientation estimate.
Gesture Detection Pipeline
High-level diagram of the gesture detection process
Our gesture detection follows a sophisticated pipeline that begins with sensor data acquisition, where
we read
raw values from the flex sensors and IMU at a consistent sampling rate. The system then applies signal
processing techniques, including the aforementioned filtering and averaging methods, to reduce noise and
extract
meaningful features from the raw data.
In the feature extraction stage, we convert these processed readings into meaningful descriptors. For
flex
sensors, we categorize finger positions into three states (straight, half-bent, or fully bent) based on
carefully calibrated threshold values that were determined through experimental testing. For IMU data,
we
convert raw accelerometer and gyroscope readings into angular measurements that describe the hand's
orientation
in three-dimensional space.
The gesture classification stage is where the system matches these extracted features against our
predefined
gesture patterns. This matching process follows a hierarchical approach: first, it checks if the flex
sensor
patterns match; then, if contact sensors are used for a gesture, it verifies th
Technologies used
Hardware components
- RP2040
- Raspberry Pi Pico
- IMU
- MPU6050
- gyroscope
- accelerometer
- ADC
Software & tools
- C
- Arduino IDE
Project demo video
What you get
- Working project / hardware kit, tested before delivery
- Complete source code with explanation
- Project demo and guidance for your viva
- Project report, PPT and IEEE paper support (on request)
Delivery & Payment
Delivery takes a minimum of two weeks from the date your inquiry is confirmed.
Payment is in two parts:
• 50% advance to start the project
• Remaining 50% before delivery
Note:
• Documentation and PPT are not included by default
• If you need documentation/PPT, it can be arranged for extra time and cost
We'll confirm the exact timeline and cost with you after reviewing your requirements.
Related Embedded Systems projects

Embedded Systems
Gas Leakage Detector Using Arduino
A budget-friendly LPG gas leak detector built with an Arduino and MQ-5 gas sensor, triggering a buzzer and LED when unsafe gas levels are de...
View project
Embedded Systems
Simple Alarm System
A beginner-friendly home alarm with PIR motion sensing, keypad PIN entry, and separate entry/exit timing delays, built to be easy to expand.
View project
Embedded Systems
Ultrasonic Sensor Project with Arduino UNO Q
A beginner-friendly first Arduino UNO Q project: a servo-swept ultrasonic sensor that renders a live sweeping radar display in a web browser...
View project
Embedded Systems
3D Audio Localization
[Fall 2025] We designed a real-time embedded system that localizes sound sources in three dimensions and visualizes them live using a four-m...
View project