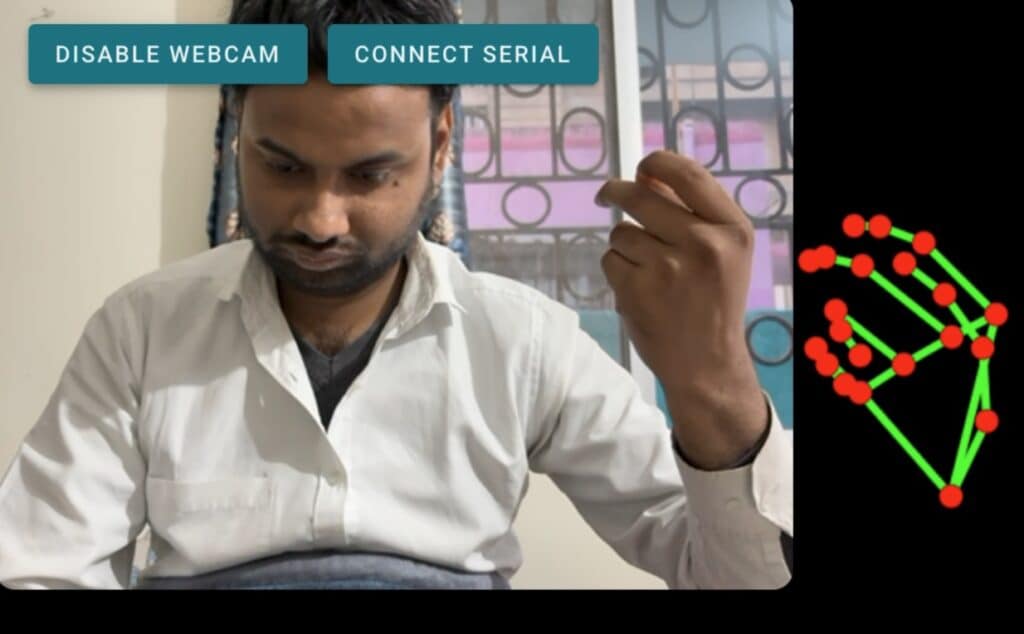
AI-Based Hand Tracking for Robotic Arm Control
In this project, I show how to control a robotic arm servo using real-time hand tracking powered by AI image processing
- Suitable forB.Tech AI students
- Build time3-4 weeks
- LevelBeginner
- Available atAjvika Labs, Kakinada
About this project
In this project, I show how to control a robotic arm servo using real-time hand tracking powered by AI image processing. We use MediaPipe for fast hand detection, a web browser for processing camera input, and an IndusBoard Coin to translate hand movement into servo motion. The result is a simple but powerful human-machine interface that connects hand gestures directly to robot movement.
AI image processing has become one of the most practical tools in modern robotics. From factory automation to human-machine interfaces, vision-based control systems are now replacing traditional input devices.
In this project, I combine real-time hand tracking with robotic control to demonstrate how natural hand movements can directly control a servo motor. The idea is simple. Your hand becomes the controller, and the robot responds instantly.
This approach is especially useful in industrial environments where touchless control is preferred, such as welding stations, assembly lines, soldering setups, and training simulators.
Why MediaPipe Is Used for Hand Tracking
For hand detection and tracking, I use the MediaPipe hand tracking model. It is fast, lightweight, and works efficiently inside a web browser. MediaPipe detects key hand landmarks and provides accurate x, y, and z coordinates in real time.
These coordinates are exactly what we need to translate human hand movement into robotic motion without adding extra sensors or hardware.
How the Hand Tracking Robot Control System Works
The complete system works in three simple stages:
A webcam captures live video of your hand.
MediaPipe processes the video and extracts hand movement coordinates.
These coordinates are sent to the IndusBoard Coin through the WebSerial API.
The IndusBoard Coin maps the received values to a servo motor using PWM.
This makes the browser act as the AI brain, while the controller board handles motor control.
You only need a few components to build this project:
This minimal setup makes the project easy to replicate and scale.
For the servo motor, you can use any free PWM-compatible pin on the IndusBoard Coin. All standard servo motors work with PWM signals, so pin selection is flexible.
In this demo, I use only one servo motor to control movement along different axes using mapped hand coordinates. If you want to expand the system, you can modify the code to control multiple servo motors for full robotic arm motion.
Software Architecture and Code Overview
The project uses two separate programs working together.
The first part is an HTML-based web page that runs the MediaPipe hand tracking model. This page accesses your webcam, detects hand landmarks, and extracts finger coordinates.
Using the WebSerial API, the browser sends these coordinates directly to the IndusBoard Coin over USB.
The second part runs on the IndusBoard Coin using the Arduino IDE. Here, I use the esp32servo library to generate PWM signals for the servo motor.
The board continuously listens for serial data from the browser. Once coordinate values are received, they are mapped to servo angles, allowing smooth and responsive motor movement.
Note: You can download the complete code, given at the end of the article.
Testing the Hand Tracking Robot Control System
Once the code is uploaded and everything is connected, testing is straightforward.
Open the HTML file in a supported browser and click the Connect Serial button. Select the IndusBoard Coin from the device list. After the connection is established, enable the webcam.
At this point, the system starts tracking your hand in real time. As you move your hand, the servo motor responds instantly, mimicking your motion.
This is where AI image processing truly feels alive.
Applications of AI Hand Tracking in Robotics
This project is not just a demo. It can be extended to real-world applications such as:
Human-machine interfaces for industrial robots
Touchless control panels in factories
Educational robotics and AI learning kits
Research prototypes for collaborative robots
What I like most about this project is how accessible AI-powered robotics has become. With just a browser, a camera, and a small controller board, you can build an intuitive robot control system that feels natural and futuristic.
If you are exploring AI image processing, robotics, or human-machine interfaces, this project is a great place to start.
SHARE YOUR THOUGHTS & COMMENTS Register or Login to leave a comment.
Smart Speed Monitoring System For Road Safety
Real-Time Face Tracking Using Raspberry Pi 4 Versus Raspberry Pi 5 With Hailo-8L
High-Voltage Capacitor Discharger
Real-time Web-based Home Automation
World’s Smallest Open-Source LoRa + GPS Module for Wearables and IoT (Only 3cm!)
Smallest Spy Video Streaming Camera
Wirelessly Control Multiple AC Appliances with Web Interface
Ultra-Low-Loss Isolated Current Sensor
STMicroelectronics has Introduced First Automotive Microcontroller With built-in AI Acceleration
Samsung Launched 200MP Image Sensor Called ISOCELL HP5
Aeva Introduced 4D LiDAR Sensor for Physical AI Systems
Racetrack Shaped Resonators Enhances Light Trapping
AI Chip Uses Light Instead Of Electricity
AI Mini PC Targets Edge Computing Workloads
Battery-Free In-Tire Sensors For Autonomous Vehicles
DIY: Audio Signal–Controlled LED Display Using LM3914
State Reduction In Sequential Circuits
Make Your Own Musical Temperature Alarm
Buck Converter vs Linear Voltage Regulator
Ultra-Compact RGB LED For Space-Constrained Designs
AI image processing has become one of the most practical tools in modern robotics. From factory automation to human-machine interfaces, vision-based control systems are now replacing traditional input devices.
In this project, I combine real-time hand tracking with robotic control to demonstrate how natural hand movements can directly control a servo motor. The idea is simple. Your hand becomes the controller, and the robot responds instantly.
This approach is especially useful in industrial environments where touchless control is preferred, such as welding stations, assembly lines, soldering setups, and training simulators.
Why MediaPipe Is Used for Hand Tracking
For hand detection and tracking, I use the MediaPipe hand tracking model. It is fast, lightweight, and works efficiently inside a web browser. MediaPipe detects key hand landmarks and provides accurate x, y, and z coordinates in real time.
These coordinates are exactly what we need to translate human hand movement into robotic motion without adding extra sensors or hardware.
How the Hand Tracking Robot Control System Works
The complete system works in three simple stages:
A webcam captures live video of your hand.
MediaPipe processes the video and extracts hand movement coordinates.
These coordinates are sent to the IndusBoard Coin through the WebSerial API.
The IndusBoard Coin maps the received values to a servo motor using PWM.
This makes the browser act as the AI brain, while the controller board handles motor control.
You only need a few components to build this project:
This minimal setup makes the project easy to replicate and scale.
For the servo motor, you can use any free PWM-compatible pin on the IndusBoard Coin. All standard servo motors work with PWM signals, so pin selection is flexible.
In this demo, I use only one servo motor to control movement along different axes using mapped hand coordinates. If you want to expand the system, you can modify the code to control multiple servo motors for full robotic arm motion.
Software Architecture and Code Overview
The project uses two separate programs working together.
The first part is an HTML-based web page that runs the MediaPipe hand tracking model. This page accesses your webcam, detects hand landmarks, and extracts finger coordinates.
Using the WebSerial API, the browser sends these coordinates directly to the IndusBoard Coin over USB.
The second part runs on the IndusBoard Coin using the Arduino IDE. Here, I use the esp32servo library to generate PWM signals for the servo motor.
The board continuously listens for serial data from the browser. Once coordinate values are received, they are mapped to servo angles, allowing smooth and responsive motor movement.
Note: You can download the complete code, given at the end of the article.
Testing the Hand Tracking Robot Control System
Once the code is uploaded and everything is connected, testing is straightforward.
Open the HTML file in a supported browser and click the Connect Serial button. Select the IndusBoard Coin from the device list. After the connection is established, enable the webcam.
At this point, the system starts tracking your hand in real time. As you move your hand, the servo motor responds instantly, mimicking your motion.
This is where AI image processing truly feels alive.
Applications of AI Hand Tracking in Robotics
This project is not just a demo. It can be extended to real-world applications such as:
Human-machine interfaces for industrial robots
Touchless control panels in factories
Educational robotics and AI learning kits
Research prototypes for collaborative robots
What I like most about this project is how accessible AI-powered robotics has become. With just a browser, a camera, and a small controller board, you can build an intuitive robot control system that feels natural and futuristic.
If you are exploring AI image processing, robotics, or human-machine interfaces, this project is a great place to start.
SHARE YOUR THOUGHTS & COMMENTS Register or Login to leave a comment.
Smart Speed Monitoring System For Road Safety
Real-Time Face Tracking Using Raspberry Pi 4 Versus Raspberry Pi 5 With Hailo-8L
High-Voltage Capacitor Discharger
Real-time Web-based Home Automation
World’s Smallest Open-Source LoRa + GPS Module for Wearables and IoT (Only 3cm!)
Smallest Spy Video Streaming Camera
Wirelessly Control Multiple AC Appliances with Web Interface
Ultra-Low-Loss Isolated Current Sensor
STMicroelectronics has Introduced First Automotive Microcontroller With built-in AI Acceleration
Samsung Launched 200MP Image Sensor Called ISOCELL HP5
Aeva Introduced 4D LiDAR Sensor for Physical AI Systems
Racetrack Shaped Resonators Enhances Light Trapping
AI Chip Uses Light Instead Of Electricity
AI Mini PC Targets Edge Computing Workloads
Battery-Free In-Tire Sensors For Autonomous Vehicles
DIY: Audio Signal–Controlled LED Display Using LM3914
State Reduction In Sequential Circuits
Make Your Own Musical Temperature Alarm
Buck Converter vs Linear Voltage Regulator
Ultra-Compact RGB LED For Space-Constrained Designs
Technologies used
Hardware components
- ESP32
- Arduino
- Raspberry Pi
- Motor
- Servo
- MPU
- LED
- Button
- Sensor
- Module
- Board
- Capacitor
- Battery
- Camera
- GPS
Software & tools
- Arduino IDE
What you get
- Working project / hardware kit, tested before delivery
- Complete source code with explanation
- Project demo and guidance for your viva
- Project report, PPT and IEEE paper support (on request)
Delivery & Payment
Delivery takes a minimum of two weeks from the date your inquiry is confirmed.
Payment is in two parts:
• 50% advance to start the project
• Remaining 50% before delivery
Note:
• Documentation and PPT are not included by default
• If you need documentation/PPT, it can be arranged for extra time and cost
We'll confirm the exact timeline and cost with you after reviewing your requirements.
Related AI projects

AI
ESP32 CAM Object Detection using Edge Impulse TinyML
Deploy a custom TinyML object detection model trained on Edge Impulse on ESP32-CAM to identify objects like vegetables, gestures or products...
View project
AI
ESP32 Real-Time Face Recognition Attendance System
Build a face recognition attendance system using ESP32-CAM that automatically logs attendance with timestamp to Firebase when a registered f...
View project
AI
C++ Programming Language
C++ Programming Language — a beginner AI project built with HTML5, CSS3, JavaScript, complete with design details, implementation steps and...
View project
AI
How to use ESP32 Camera Module for Video Streaming and Face Recognition
In this project, we are going to build a Face Recognition System using ESP32-CAM which will also work as an ESP32-CAM Security system by rec...
View project