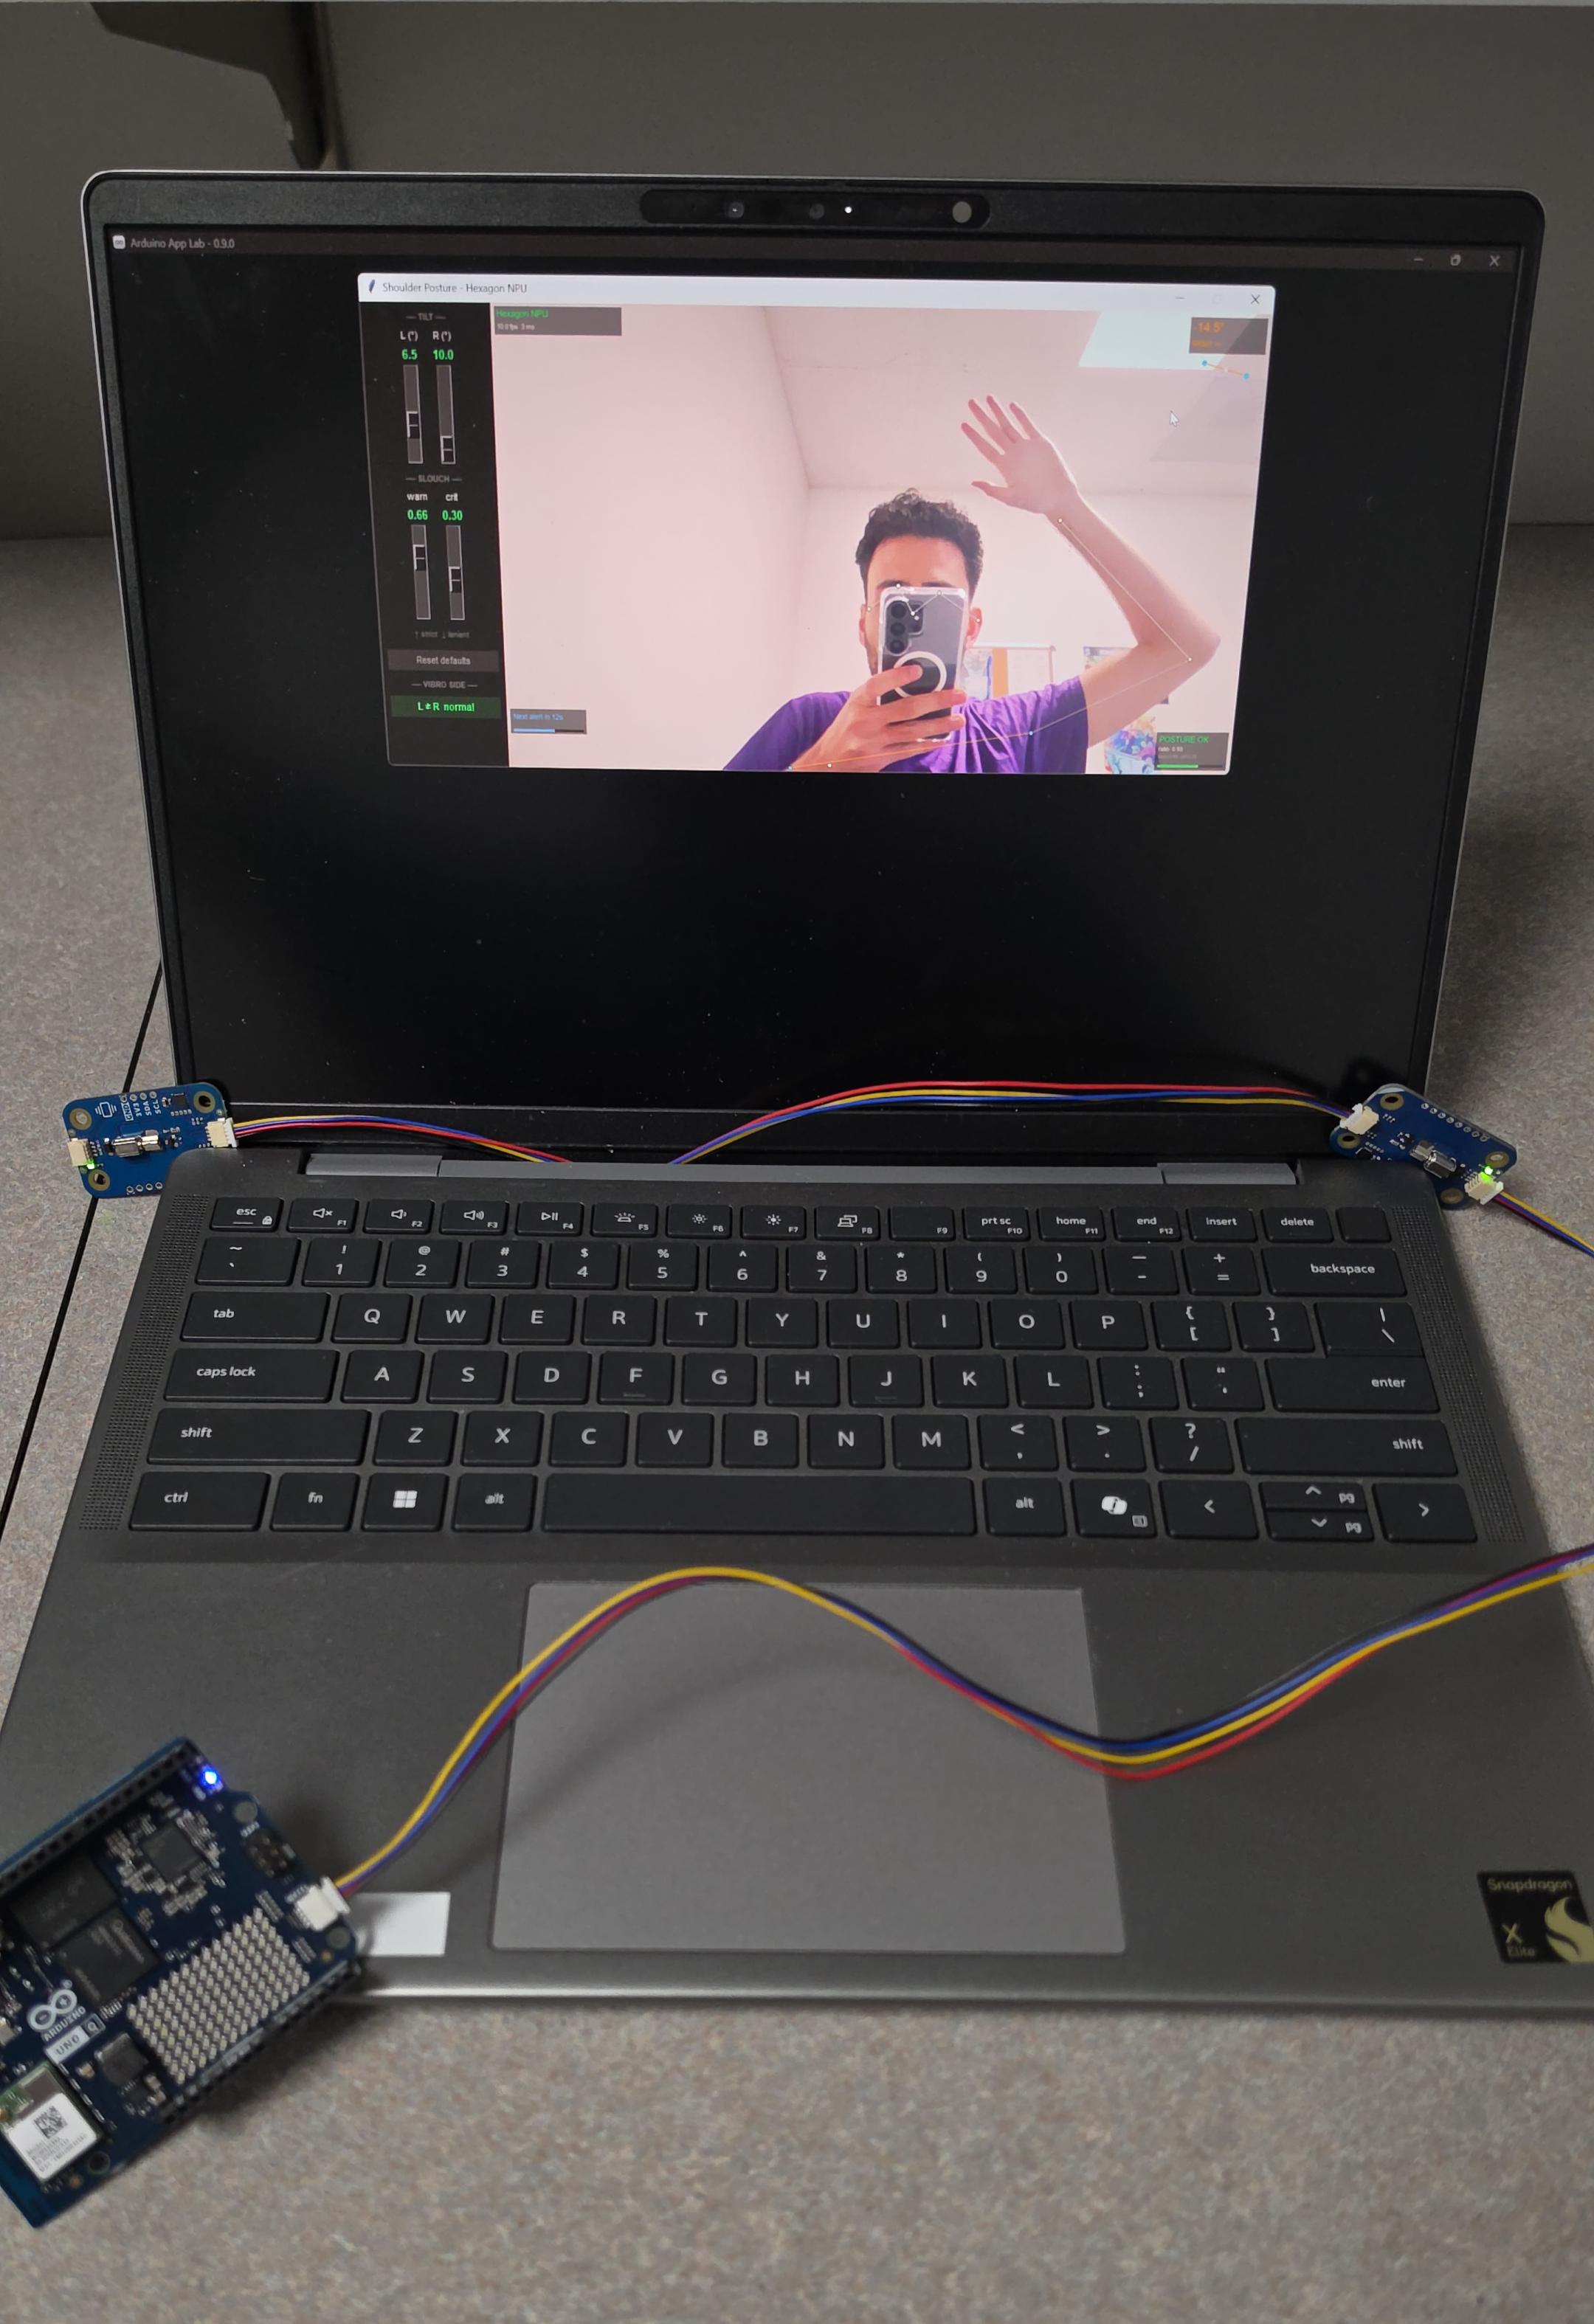
SnapSenseQ, a personalized local posture correction system!
Running entirely local on SnapDragon NPU, a posture model sends haptic feedback to UNO Q Vibros to correct user and simultaneously provide LLM feedback using agentic framework with user history.
- Suitable forB.Tech & M.Tech Computer Vision students
- Build time1-2 weeks
- LevelIntermediate
- Available atAjvika Labs, Kakinada
About this project
A personalized posture-correction system that runs entirely on a Snapdragon NPU: a posture-tracking model triggers haptic feedback through the UNO Q's vibration motor to correct the user in the moment, while an agentic LLM layer also gives feedback informed by the user's history.
Source: Arduino Project Hub (https://projecthub.arduino.cc/emregumus37/snapsenseq-a-personalized-local-posture-correction-system-004acc) by emregumus37. On Arduino Project Hub: 66 views, 0 respects.
Source: Arduino Project Hub (https://projecthub.arduino.cc/emregumus37/snapsenseq-a-personalized-local-posture-correction-system-004acc) by emregumus37. On Arduino Project Hub: 66 views, 0 respects.
Technologies used
What you get
- Working project / hardware kit, tested before delivery
- Complete source code with explanation
- Project demo and guidance for your viva
- Project report, PPT and IEEE paper support (on request)
Delivery & Payment
Delivery takes a minimum of two weeks from the date your inquiry is confirmed.
Payment is in two parts:
• 50% advance to start the project
• Remaining 50% before delivery
Note:
• Documentation and PPT are not included by default
• If you need documentation/PPT, it can be arranged for extra time and cost
We'll confirm the exact timeline and cost with you after reviewing your requirements.
Related Computer Vision projects
Computer Vision
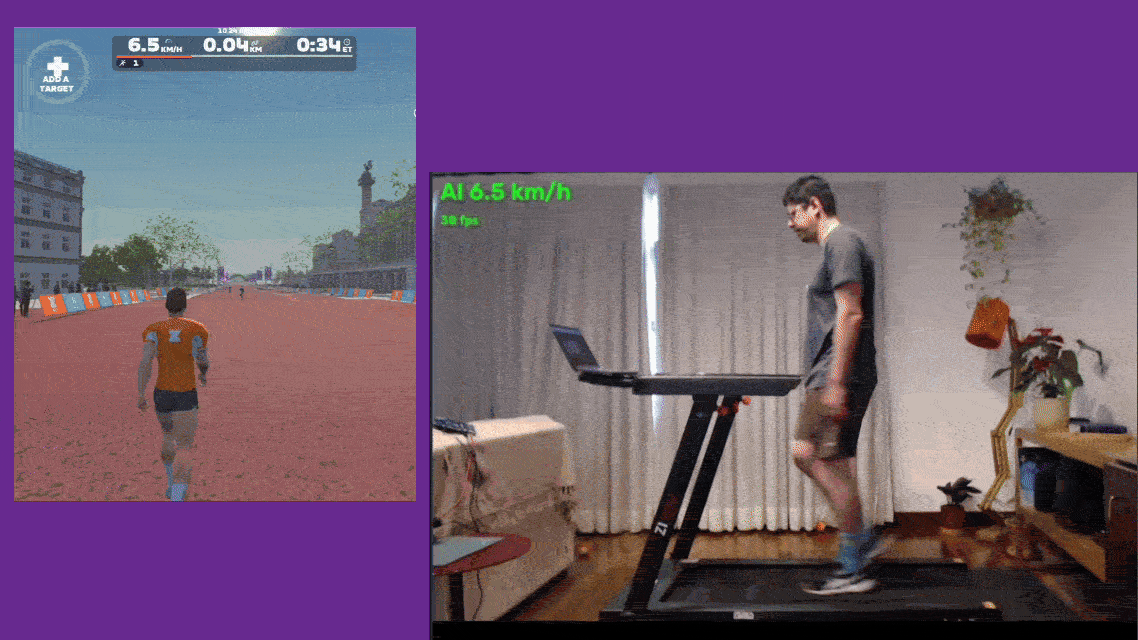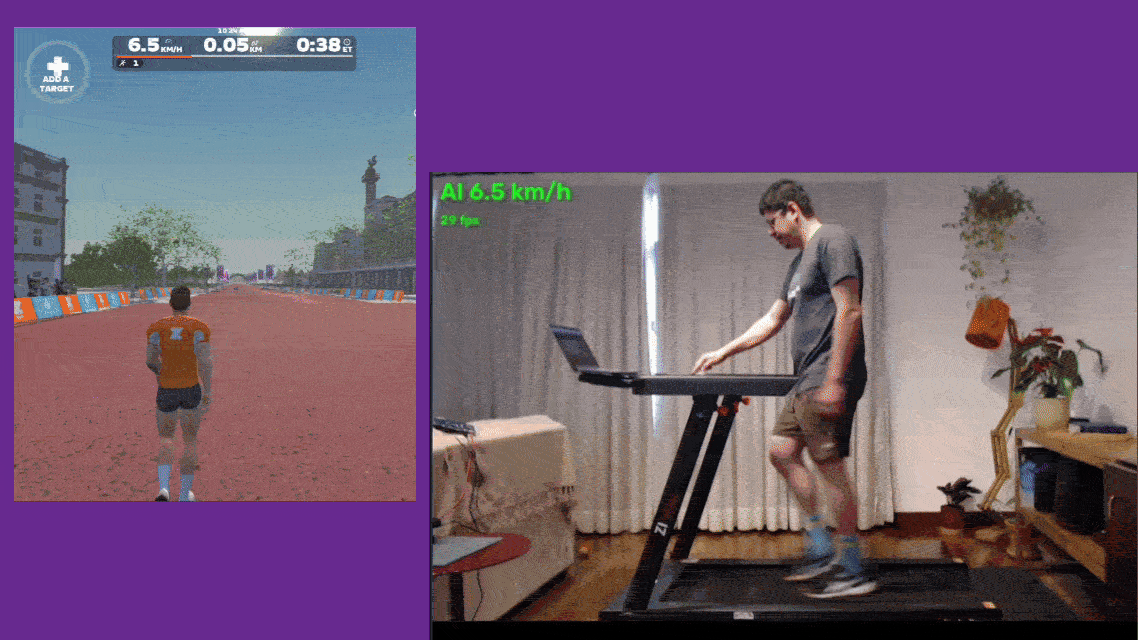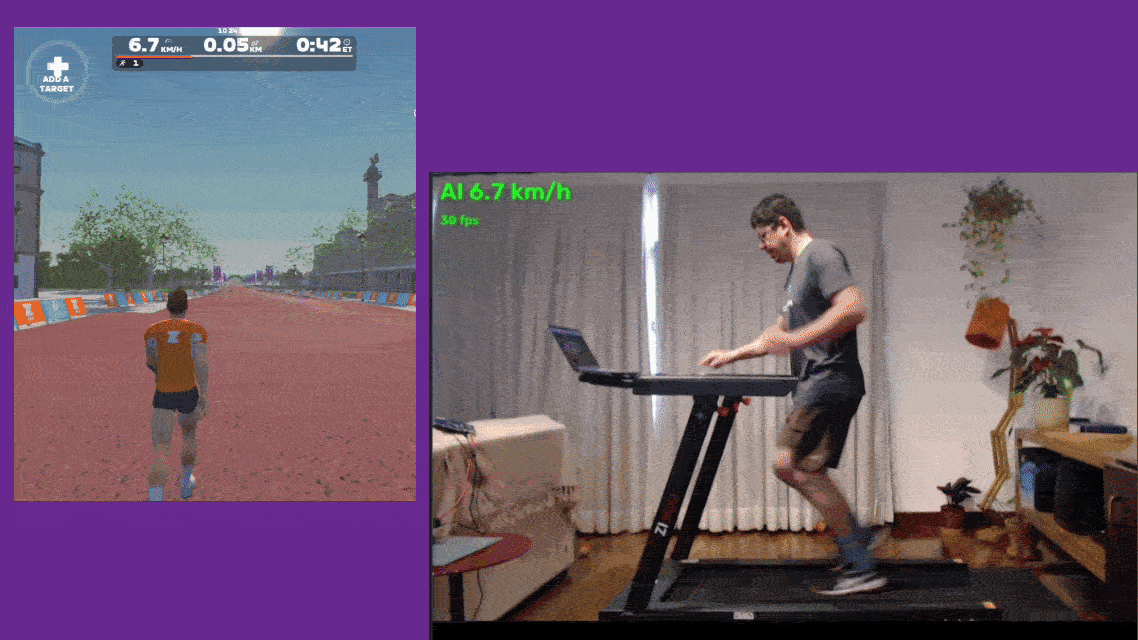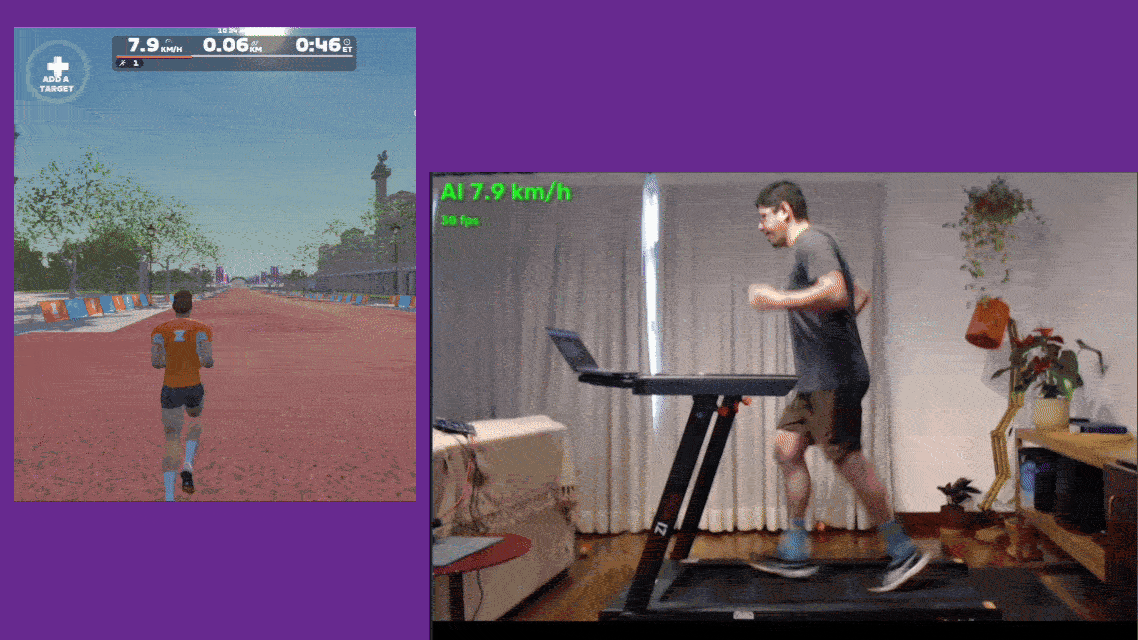
Give Your Treadmill Eyes with Edge AI
Turn any treadmill into a Bluetooth smart treadmill using a camera and Edge AI running locally on the Arduino VENTUNO Q.
View project
Computer Vision
Hand Gesture Recognition with Qualcomm Intelligent Multimedia SDK
Gesture-based interaction is becoming an increasingly important part of modern edge AI applications, enabling touchless control for robotics...
View project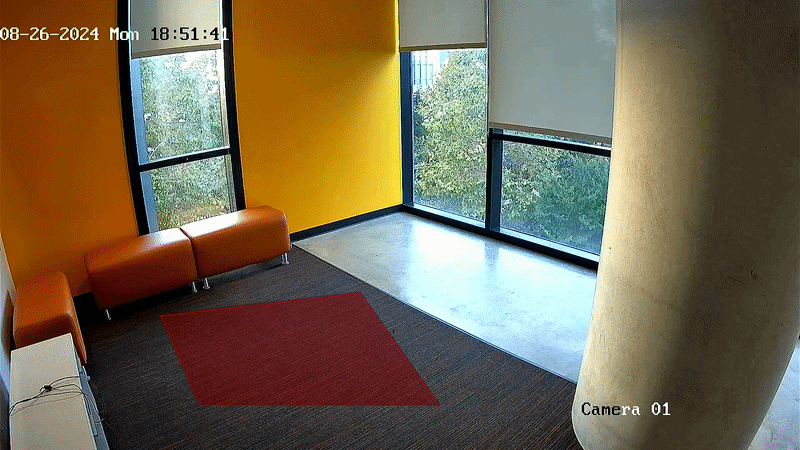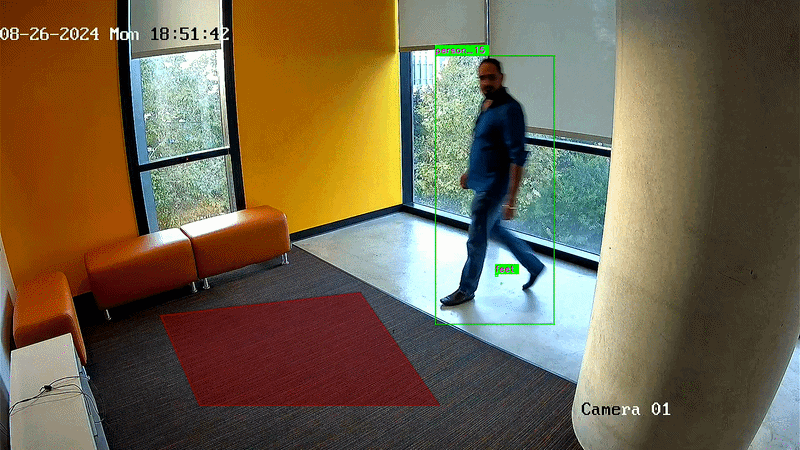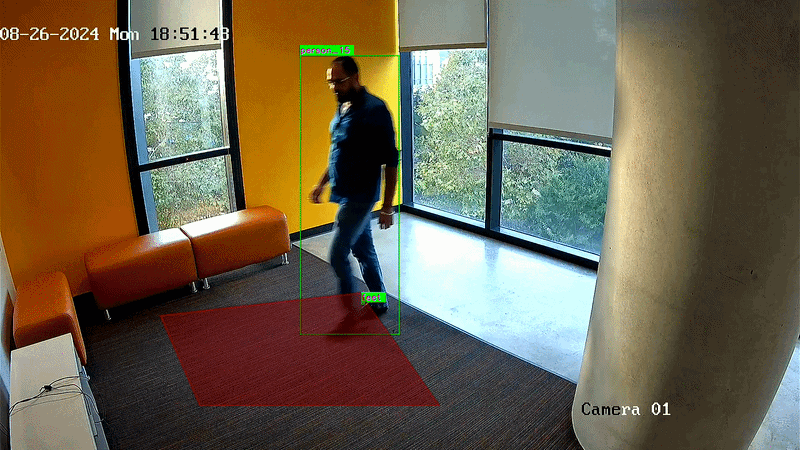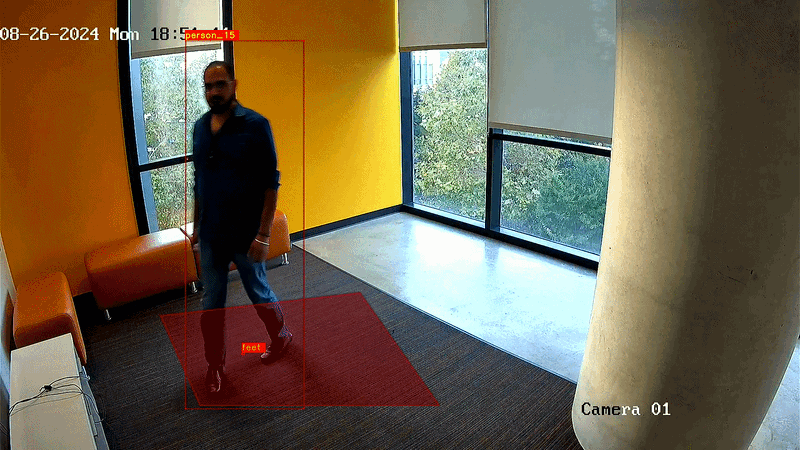
Computer Vision
Restricted Zone Violation Detection with Foot-Based Spatial Intelligence
Restricted areas are common in industrial facilities, warehouses, manufacturing environments, and other safety-critical locations. Monitorin...
View project
Computer Vision
YOLOv11 Object Detection: From CPU (4 FPS) to NPU (166 FPS) Acceleration
Modern edge AI applications require both accuracy and speed. In this project, you'll learn how to deploy and optimize a YOLOv11 object detec...
View project